Pneumatically Controlled Wearable Tactile Actuator for Multi-Modal Haptic Feedback
Wearable pneumatic actuators provide multimodal tactile feedback including vibration, pressure, impact, and lateral force in compact wearable forms.
Researchers: Ahsan Raza, Waseem Hassan, and Seokhee Jeon
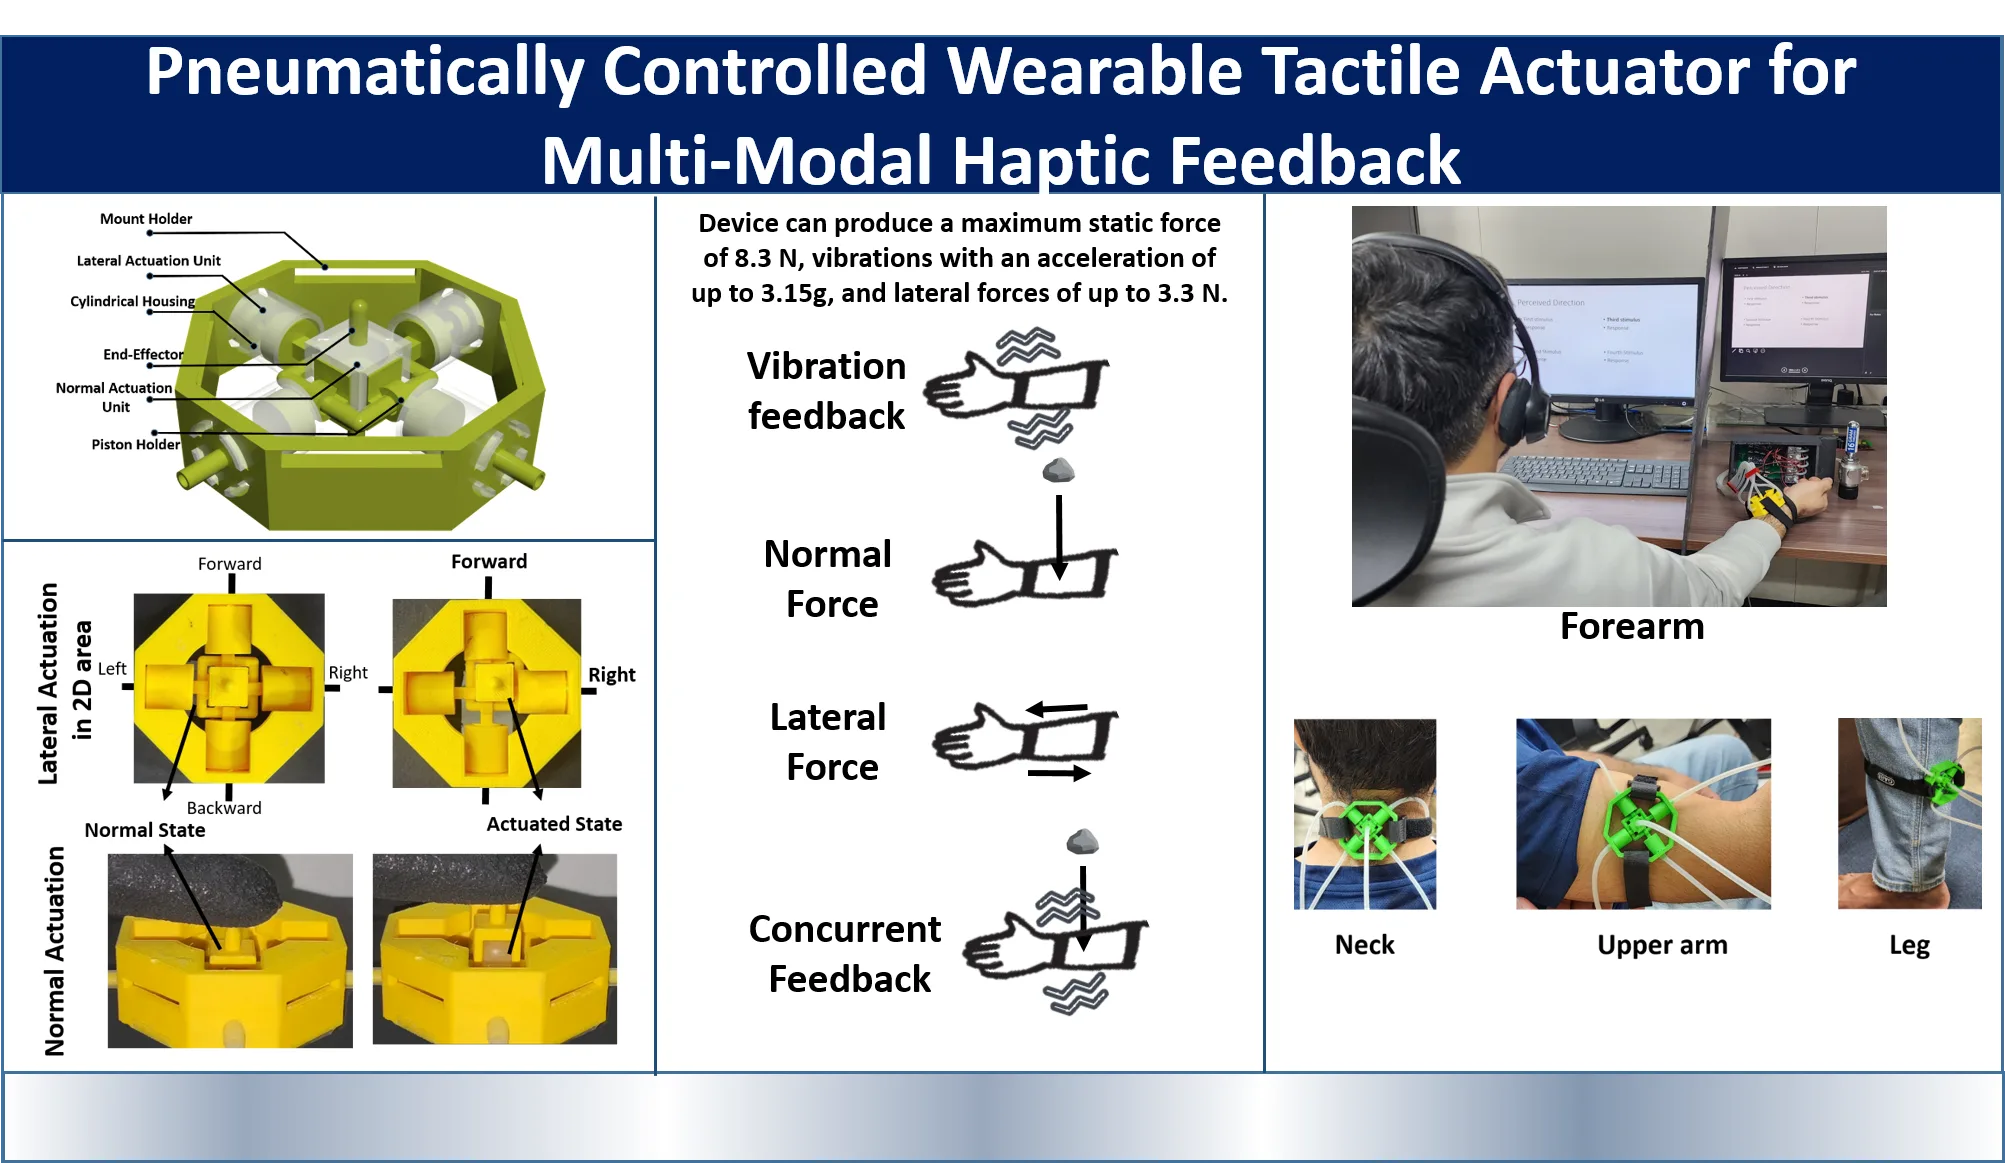
This research introduces a wearable pneumatic actuator, designed for providing multiple types of tactile feedback using a single end-effector. To this end, the actuator combines a 3D-printed framework consisting of five 0.5 DOF soft silicon air cells with a pneumatic system to deliver a range of tactile sensations through a single end-effector. The actuator is capable of producing diverse haptic feedback, including vibration, pressure, impact, and lateral force, controlled by an array of solenoid valves. It can produce a maximum static force of 8.3 N, vibrations with an acceleration of up to 3.15 g, and lateral forces of up to 3.3 N. The efficacy of the actuator is demonstrated through two distinct user studies: one focusing on perception, where users differentiated between lateral cues and vibration frequencies, and another within a first-person shooter gaming scenario, revealing enhanced user engagement and experience.
Related Publications:
- Ahsan Raza, Waseem Hassan, and Seokhee Jeon, "Pneumatically Controlled Wearable Tactile Actuator for Multi-Modal Haptic Feedback," IEEE Access, 2024.
Pictures
Papers
Pneumatically Controlled Wearable Tactile Actuator for Multi-Modal Haptic Feedback
Ahsan Raza, Waseem Hassan, Seokhee Jeon
IEEE Access, 2024 · IF 4.2 (JCR 2025)