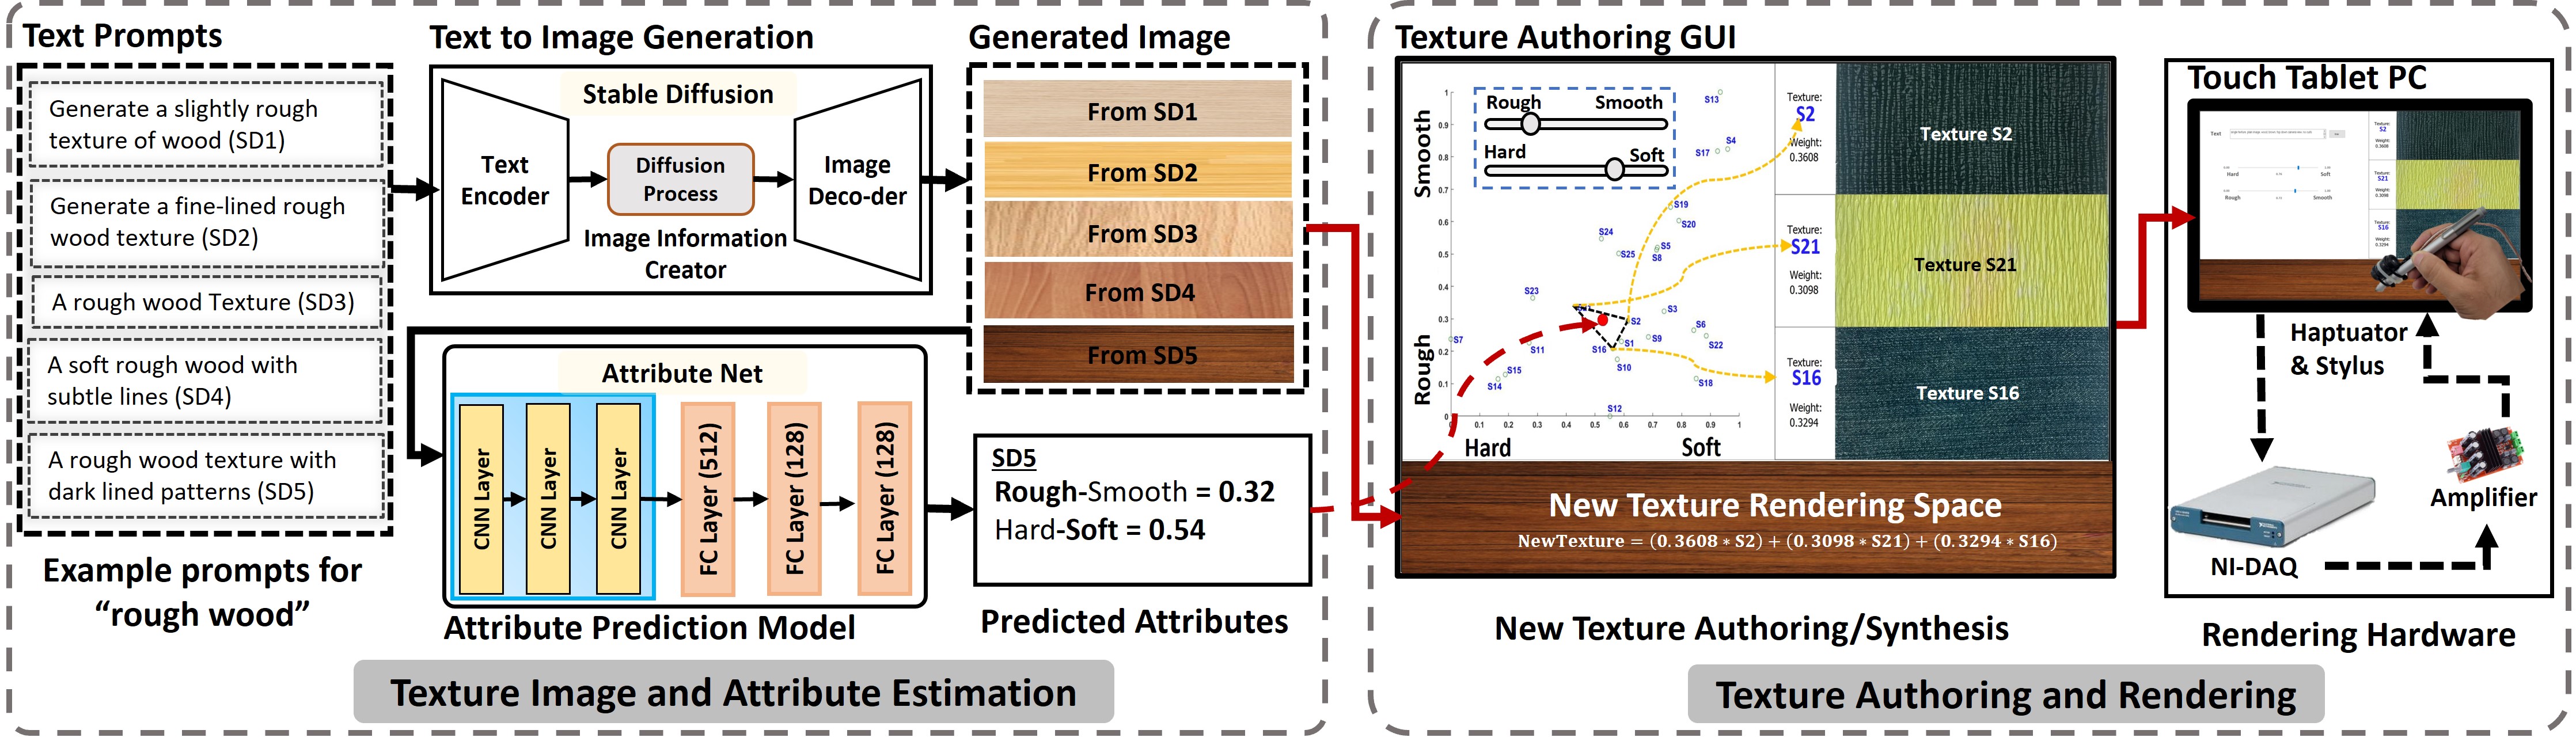
Describe a texture in words, see it as an image, and feel it as a vibration: a complete text-to-haptic pipeline (IEEE World Haptics Conference 2025).
Ongoing· 2024 to now
See details
Developing hardware and software frameworks for data-driven haptic content modeling based on stiffness, friction, and surface texture measurement data.
Ongoing· 2012.09–current
See details
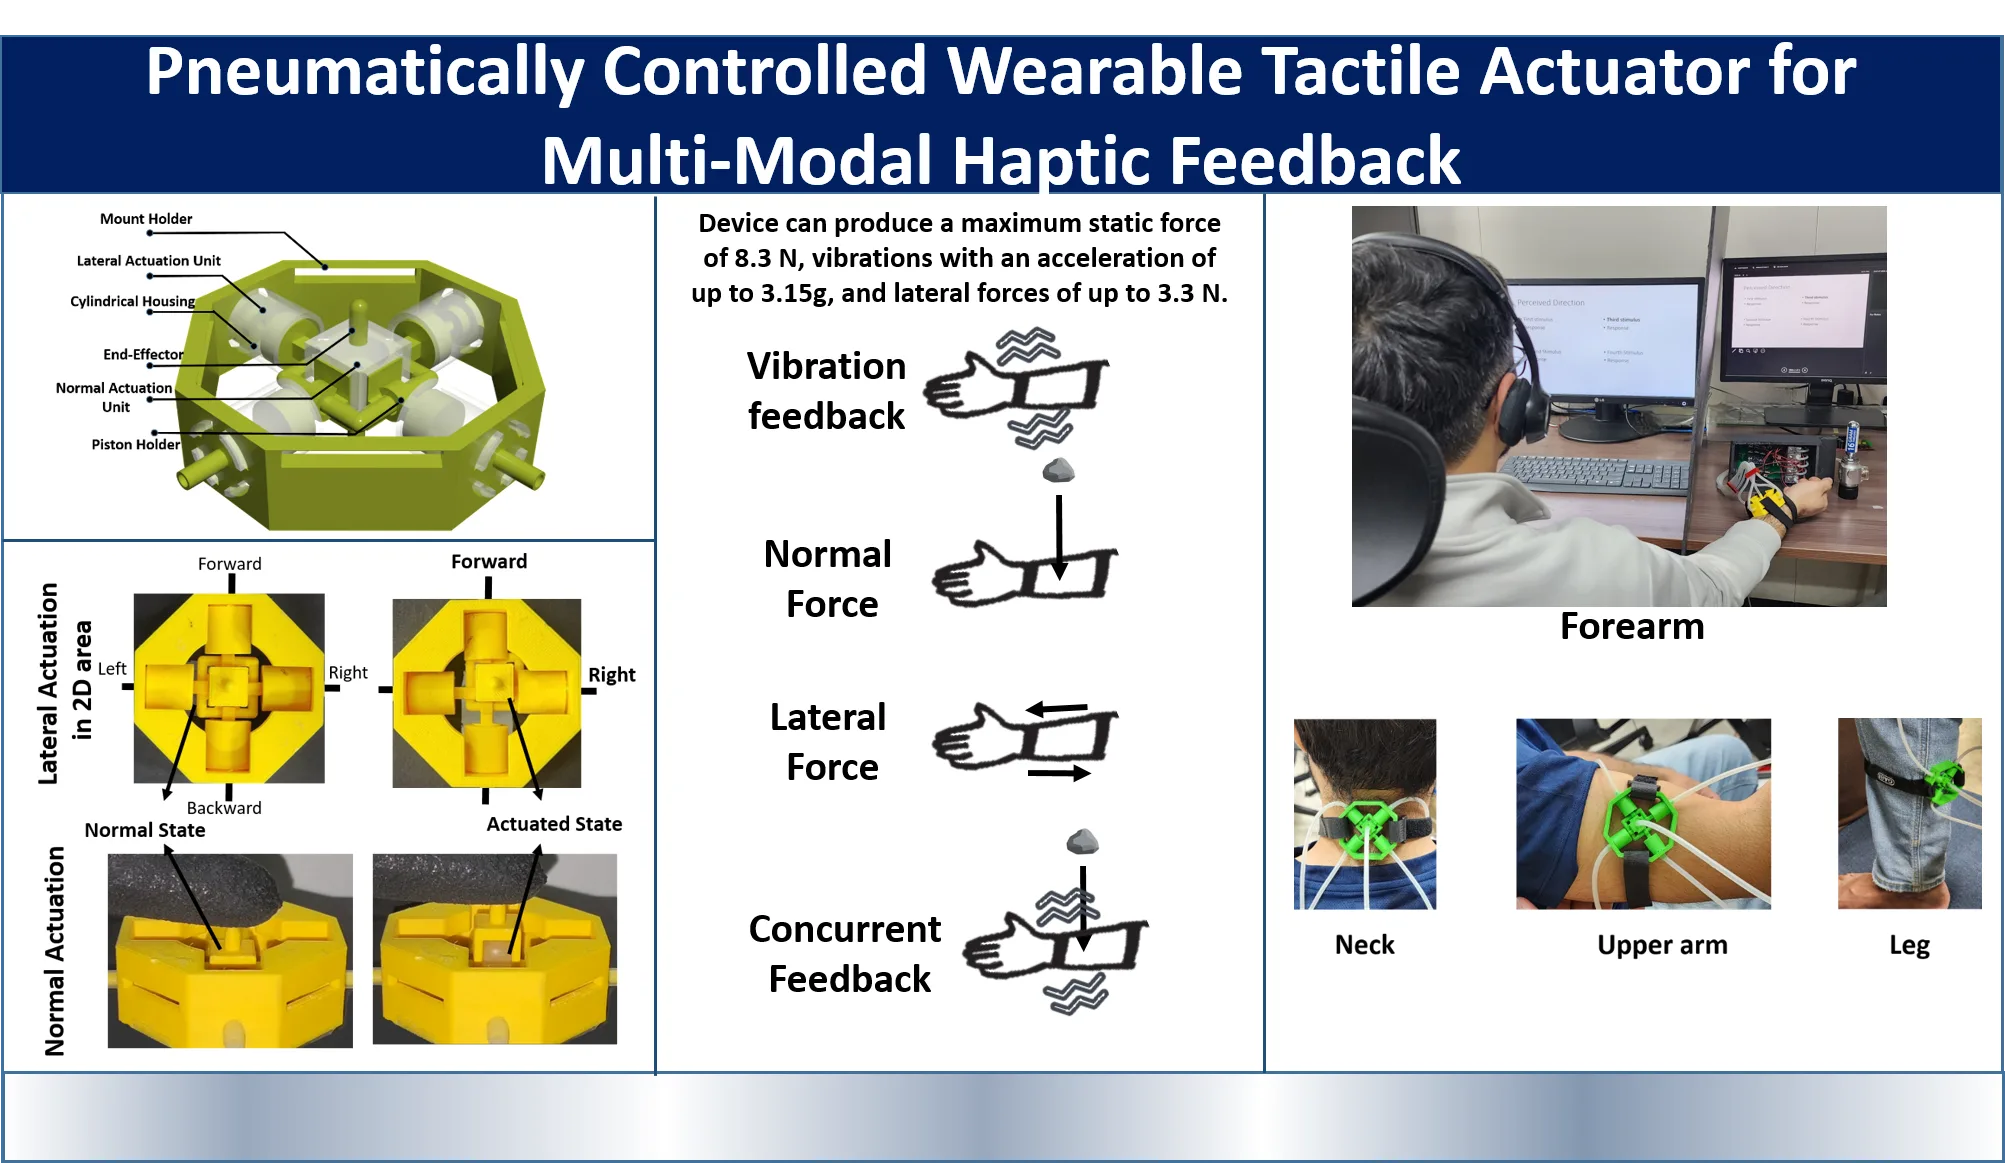
Wearable pneumatic actuators provide multimodal tactile feedback including vibration, pressure, impact, and lateral force in compact wearable forms.
Ongoing· 2021–current
See details
Model-mediated teleoperation frameworks collect remote texture signals and render stable, low-latency haptic texture feedback at the leader side.
Ongoing· 2022–current
See details
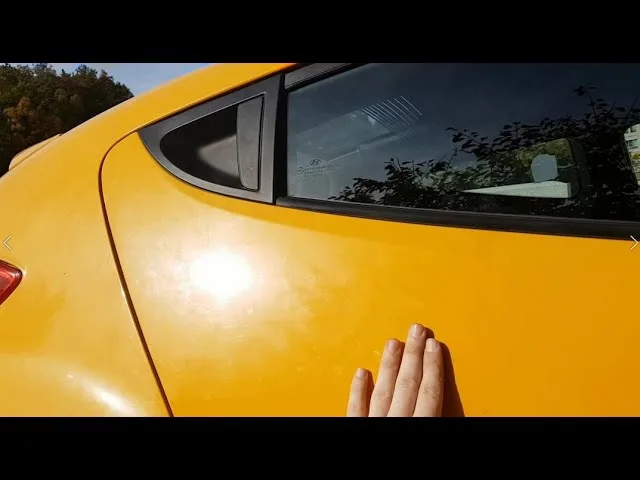
Investigating vibrotactile push-latch feedback for handleless automotive doors, enabling intuitive one-touch door opening without a physical handle.
Ongoing
See details
A light-weight, finger-worn ring actuator based on a soft pneumatic bladder that renders both static pressure and high-frequency vibrotactile feedback up to 250 Hz through fast valve control, demonstrated in VR/AR applications.
Ongoing
See details
A generalized palpation training platform combining electro-pneumatic hardware, silicone-made actuators, and body mannequins to simulate diverse medical abnormalities across prostate, thyroid, and pulse palpation scenarios.
Completed
See details
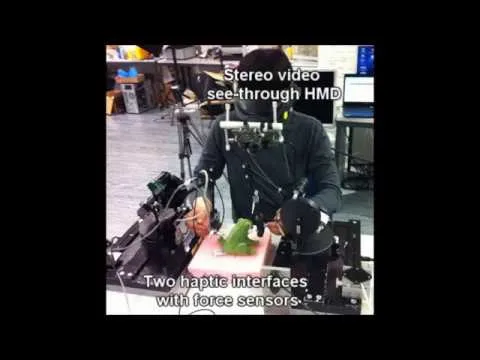
Research on modulating real object stiffness, friction, weight, and tactile properties through haptic interfaces for palpation, training, and interactive experiences.
Completed· 2009
See details
An encountered-type kinesthetic haptic interface using a drone to generate controllable force feedback for stiffness and weight rendering.
Completed
See details
A highly flexible, programmable prostate palpation simulator using a pneumatic-driven, property-changing silicone mock-up with multi-layered bladder cells that mimic stiffness, size, and nodule changes, validated by medical professionals as more realistic than conventional simulators.
Completed
See details
Pure data-driven modeling and rendering of stiffness, friction, and haptic texture based on measured interaction signals, enabling realistic haptic responses without explicit physical modeling of the target object.
Completed
See details
A universal end-effector for encountered-type haptic interfaces whose shape and stiffness can be systematically altered, overcoming the limited generality of fixed, pre-shaped end effectors.
Completed· 2012.09
See details
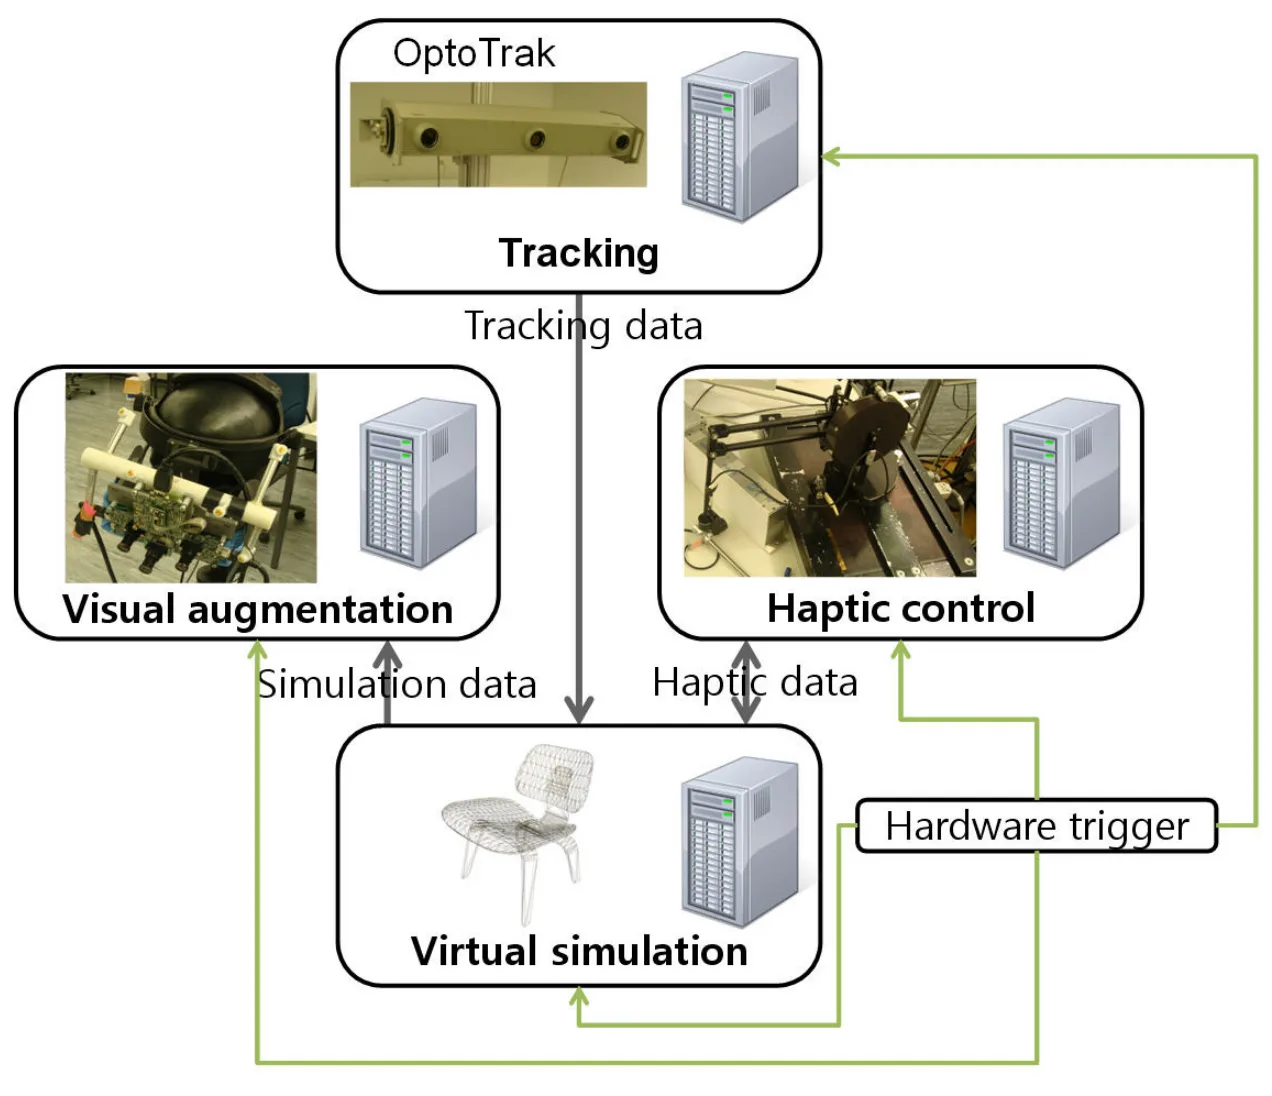
Building a framework to make a digital copy of real objects and "beam" it to a remote site, allowing a collaborator to interact with it.
Completed· 2010–2012
See details
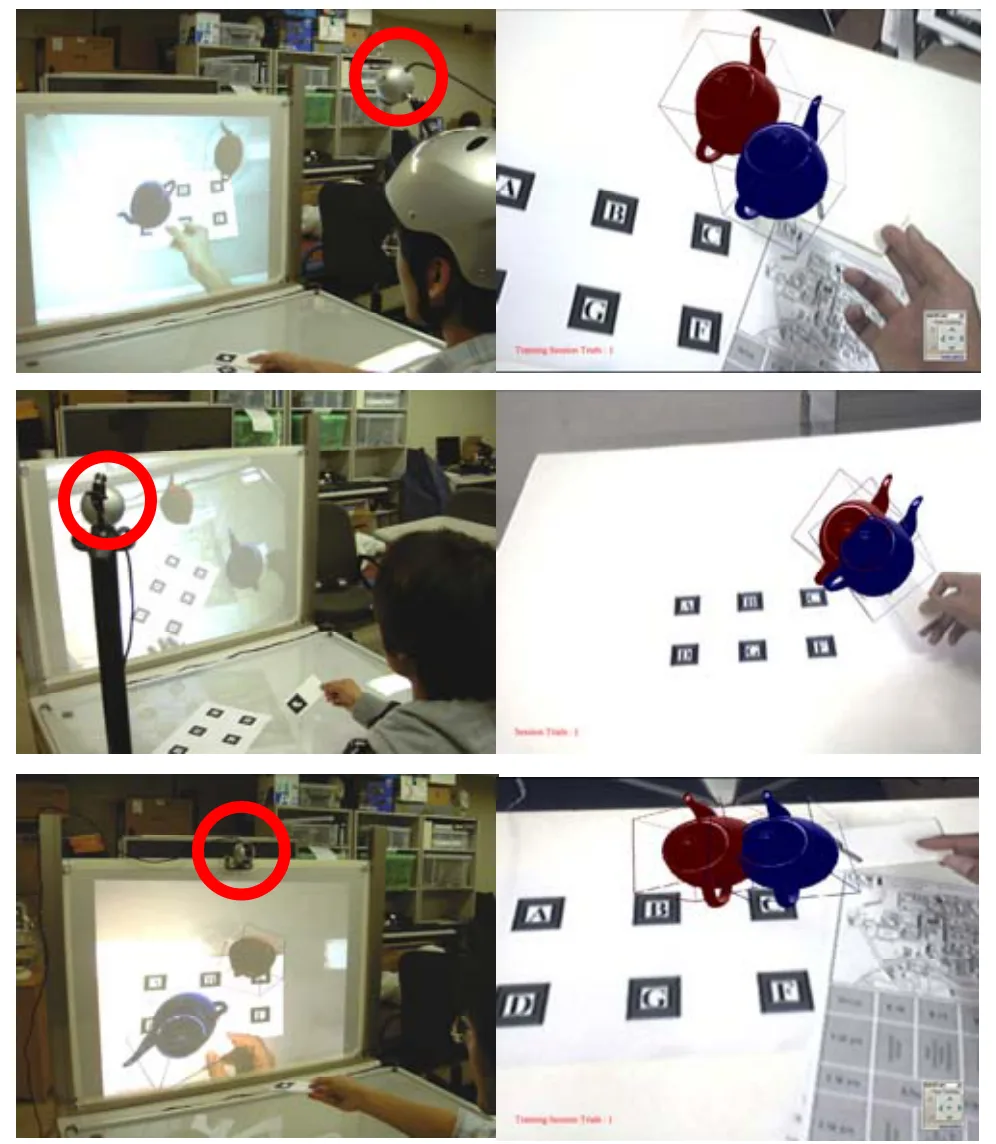
Evaluating mismatches between AR/VR/MR interfaces and their corresponding interaction objects, and seeking computational solutions to improve them.
Completed· 2006–2008
See details
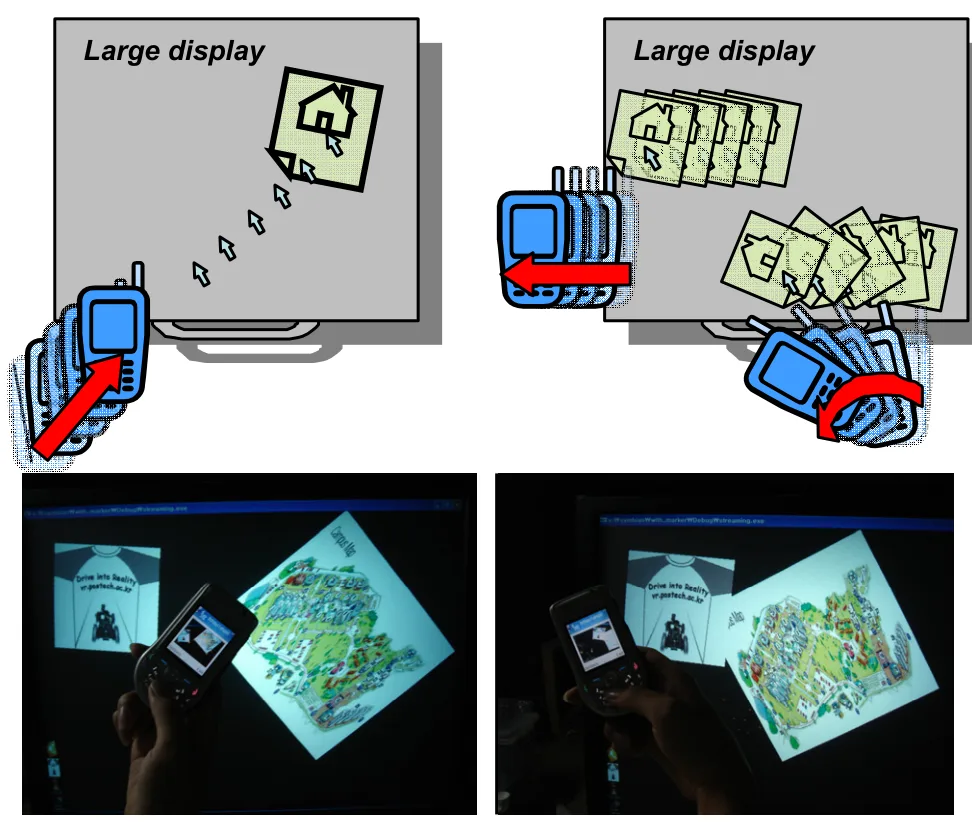
User interaction techniques using a camera-equipped hand-held device such as a mobile phone or PDA for large shared displays.
Completed· 2005–2010
See details
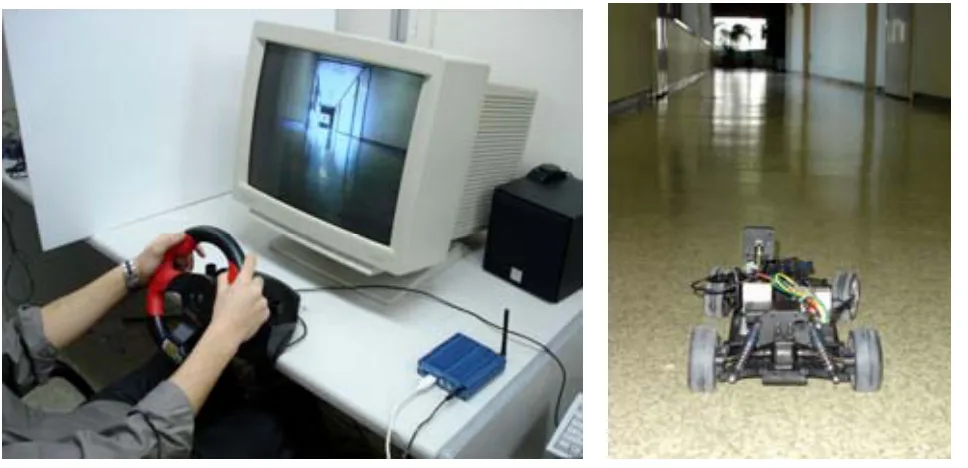
An early telepresence racing game project exploring remote interaction and control.
Completed· 2005–2006
See details
A locomotion interface allowing users to run in place within a CAVE virtual reality system.
Completed· 2003–2004
See details
An educational tool for exploring molecular geometry within an immersive CAVE virtual reality environment.
Completed· 2003
See details